Locomotion
Balance
Walking on ordinary floors is research. We are not claiming a gait, a speed, or a fall-prevention guarantee.
Products / Humanoid
Research platform · In development
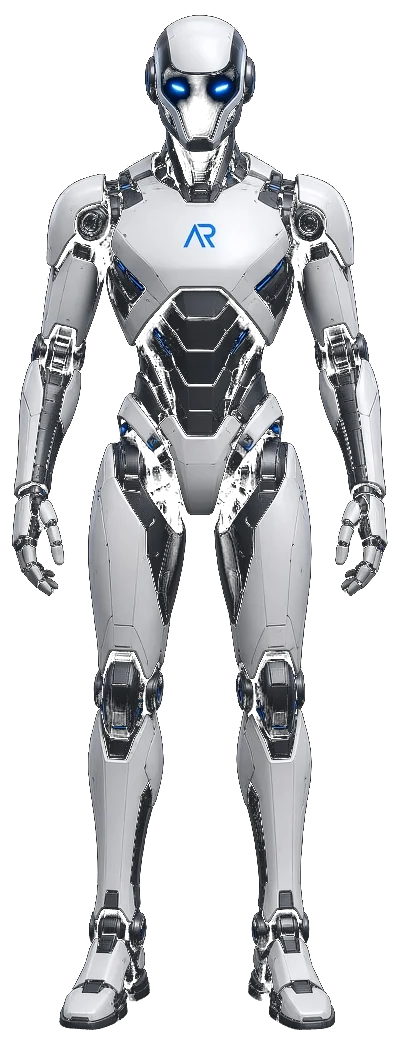
A full-size humanoid is a direction, not a catalogue product. Locomotion, hands, and perception are the problems. We will publish numbers when a machine exists to measure.
Locomotion
Walking on ordinary floors is research. We are not claiming a gait, a speed, or a fall-prevention guarantee.
Manipulation
Useful hands are part of the same long project. Dexterity will be shown with tests, not adjectives.
Perception
Vision and sensor fusion have to agree with the body. That stack is shared with the rest of the work.